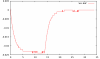
I try to calibrate my MPU6050 and face the problem that my measurement starts with a drifting approx. 20-25 seconds. Then it settles and I get a constant value. Please see graph.
I don't know how to avoid this drift. It doesn't depend on temperature. It just starts each run with such a drift.
Does anyone have an idea to fix this?
PS: I calibrate my accelerometer components manually by offseting and scaling like.
a_true=(a_measurement+a_scalar_offset)*k_gain
(Because the "def set<X,Y,Z>AccelOffset pass" are empty functions in the jeff rowbergs library)