rryba
-
Posts
1 -
Joined
-
Last visited
rryba's Achievements

Newbie (1/14)
0
Reputation
-
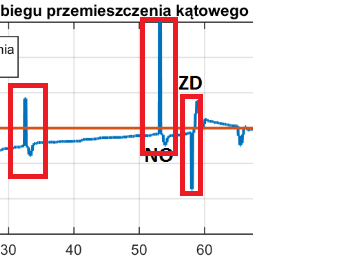
Hello, i have some problem with mpu6050, dmp euler angles returns sometimes wrong values. i am building quadcopter like stand and everyone wrong data obtained destorys stability.Look at the chart , blue line shows measured pitch angle.MPU6050 is connected to 3.3V power and without any resistors at i2c bus. Please help me !