Kim D
-
Posts
2 -
Joined
-
Last visited
Kim D's Achievements

Newbie (1/14)
0
Reputation
-
newbie No experience at all !!! GY-521 sensor
Kim D replied to Kim D's topic in I2C Protocol Analyzer
No one to help??? how do i get this fault eliminated? -
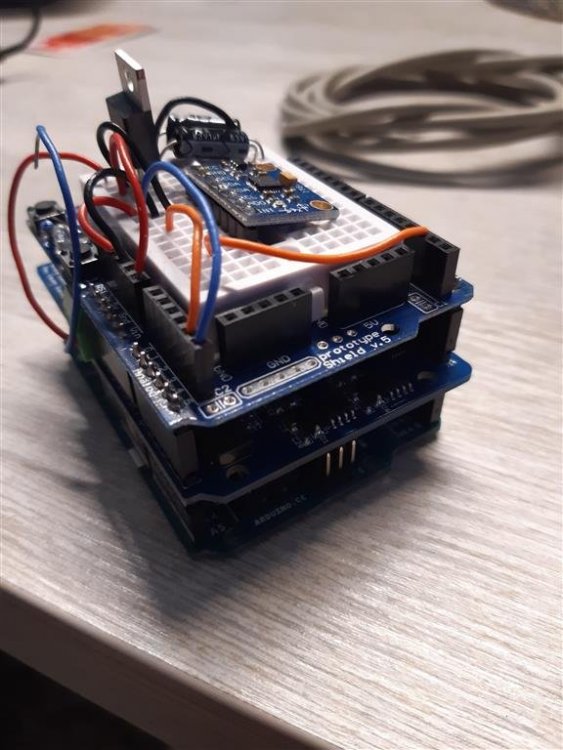
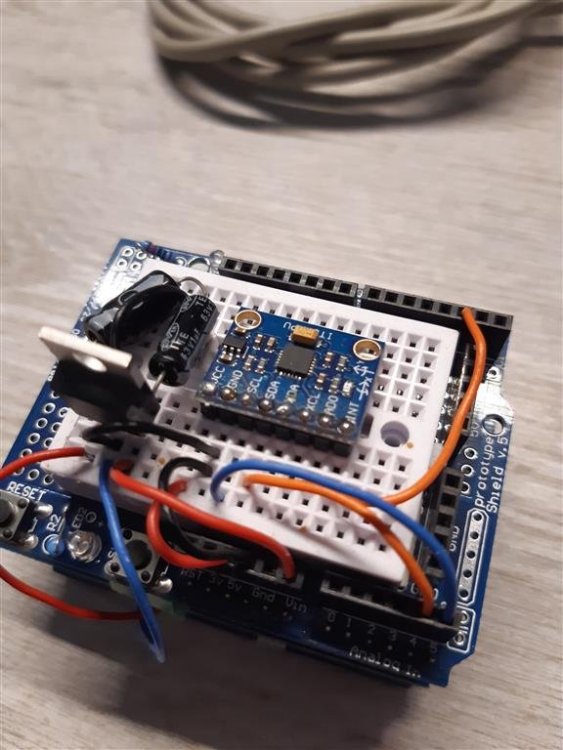
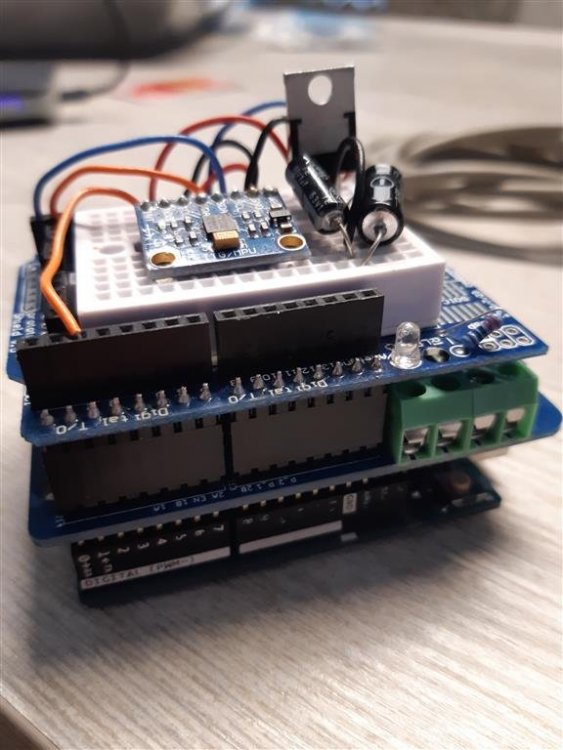
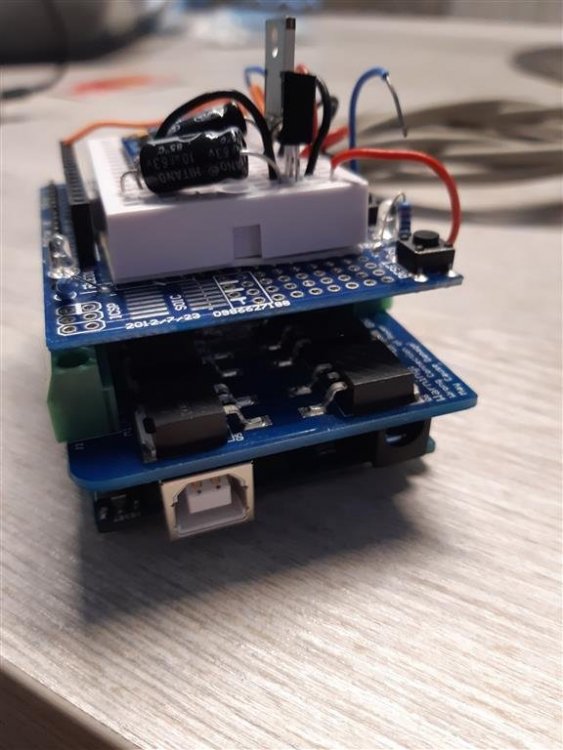
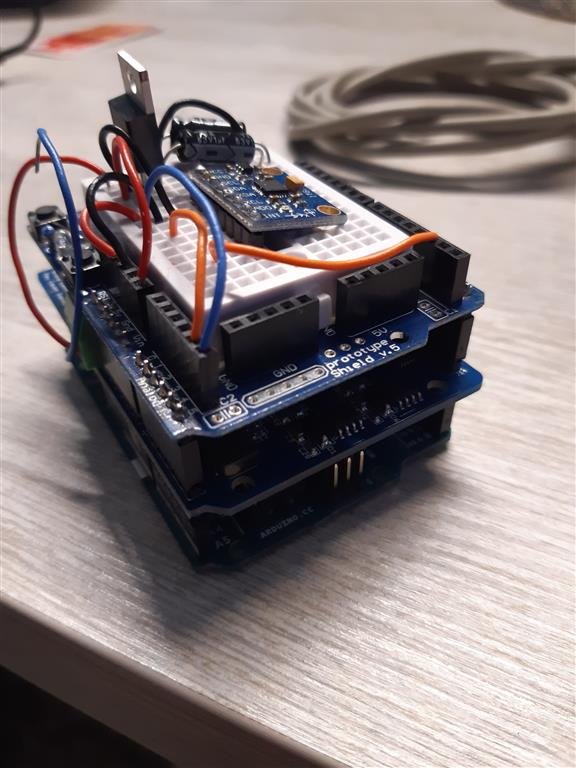
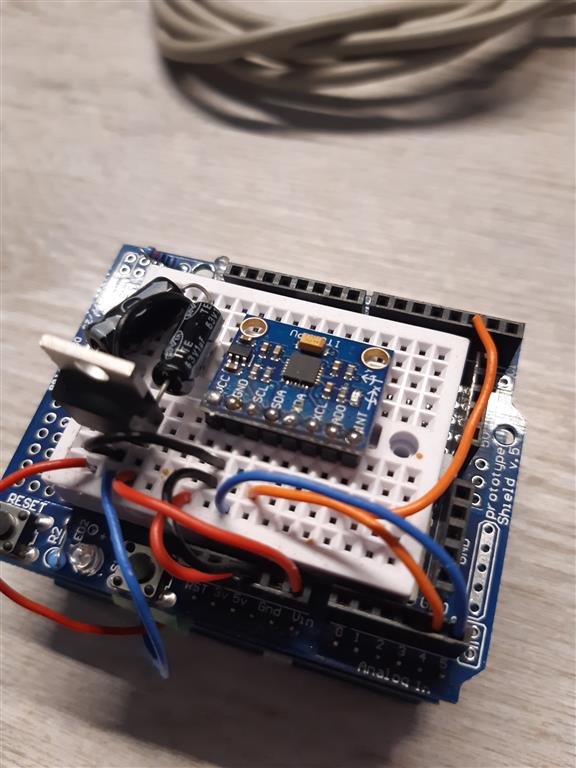
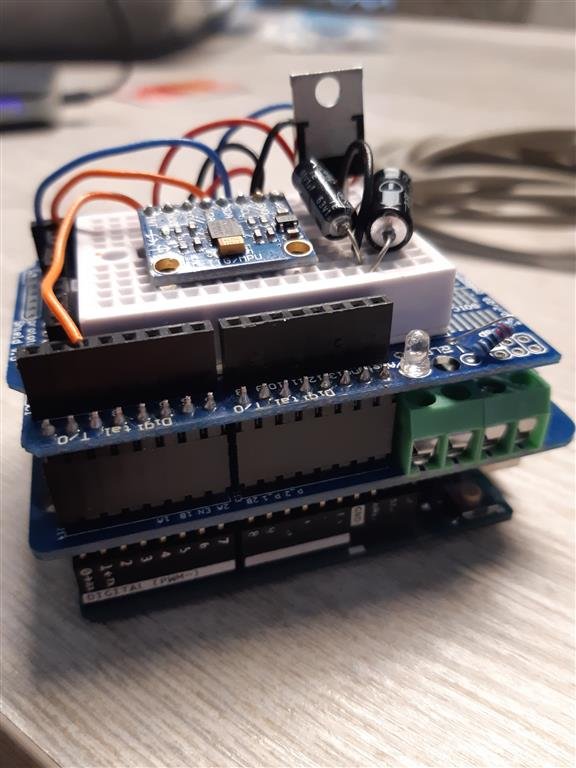
Dear, I try to restore a friends machine, that drives over un-level ground and need to hold a vertical device always perfectly vertical using 1x 12VDC motor. Stabilization is done on 1 axis. Not 2 I believe. His former old friend build a Arduino Uno board with on top a DUALCHANNEL H-BRIDGE motor shield from ELECROW.COM and on top of that board a prototype shield v.5 board containing a GY-521 sensor ( MPU 6050 I believe). We managed to get his old code back via relatives of his former friend who look like this : #include "I2Cdev.h" #include "MPU6050_6Axis_MotionApps20.h" #include "PID_v1.h" // Arduino Wire library is required if I2Cdev I2CDEV_ARDUINO_WIRE implementation // is used in I2Cdev.h #if I2CDEV_IMPLEMENTATION == I2CDEV_ARDUINO_WIRE #include "Wire.h" #endif MPU6050 mpu; // MPU control/status vars bool dmpReady = false; // set true if DMP init was successful uint8_t mpuIntStatus; // holds actual interrupt status byte from MPU uint8_t devStatus; // return status after each device operation (0 = success, !0 = error) uint16_t packetSize; // expected DMP packet size (default is 42 bytes) uint16_t fifoCount; // count of all bytes currently in FIFO uint8_t fifoBuffer[64]; // FIFO storage buffer // orientation/motion vars Quaternion q; // [w, x, y, z] quaternion container VectorFloat gravity; // [x, y, z] gravity vector float ypr[3]; // [yaw, pitch, roll] yaw/pitch/roll container and gravity vector // PID double kp = 20, ki = 0, kd = 0; double Setpoint = 0; // leveled double Input = 0, Output = 0; PID PID1(&Input, &Output, &Setpoint, kp, ki, kd, DIRECT); // ================================================================ // === INTERRUPT DETECTION ROUTINE === // ================================================================ volatile bool mpuInterrupt = false; // indicates whether MPU interrupt pin has gone high void dmpDataReady() { mpuInterrupt = true; } void setup() { // join I2C bus (I2Cdev library doesn't do this automatically) #if I2CDEV_IMPLEMENTATION == I2CDEV_ARDUINO_WIRE Wire.begin(); TWBR = 24; // 400kHz I2C clock (200kHz if CPU is 8MHz) #elif I2CDEV_IMPLEMENTATION == I2CDEV_BUILTIN_FASTWIRE Fastwire::setup(400, true); #endif // initialize serial communication Serial.begin(115200); // initialize DMP devStatus = mpu.dmpInitialize(); // Offsets for calibrating mpu.setXGyroOffset(220); mpu.setYGyroOffset(76); mpu.setZGyroOffset(-85); mpu.setZAccelOffset(1788); // 1688 factory default // make sure it worked (returns 0 if so) if (devStatus == 0) { // turn on the DMP, now that it's ready Serial.println(F("Enabling DMP...")); mpu.setDMPEnabled(true); // enable Arduino interrupt detection Serial.println(F("Enabling interrupt detection (Arduino external interrupt 0)...")); attachInterrupt(0, dmpDataReady, RISING); mpuIntStatus = mpu.getIntStatus(); // set our DMP Ready flag so the main loop() function knows it's okay to use it Serial.println(F("DMP ready! Waiting for first interrupt...")); dmpReady = true; // get expected DMP packet size for later comparison packetSize = mpu.dmpGetFIFOPacketSize(); } else { // ERROR! // 1 = initial memory load failed // 2 = DMP configuration updates failed // (if it's going to break, usually the code will be 1) Serial.print(F("DMP Initialization failed (code ")); Serial.print(devStatus); Serial.println(F(")")); } // Motor_1 controll pin initiate; pinMode(4, OUTPUT); pinMode(5, OUTPUT); pinMode(9, OUTPUT); // Speed control //Enable the Motor Shield output; pinMode(6, OUTPUT); digitalWrite(6, HIGH); //PID initiate PID1.SetMode(AUTOMATIC); PID1.SetSampleTime(1); PID1.SetOutputLimits(-255, 255); } void loop() { //If programming failed, don't try to do anything if (!dmpReady) return; // wait for MPU interrupt or extra packet(s) available while (!mpuInterrupt && fifoCount < packetSize) { // other program behavior stuff here // . // . // . // if you are really paranoid you can frequently test in between other // stuff to see if mpuInterrupt is true, and if so, "break;" from the // while() loop to immediately process the MPU data // . // . // . } // reset interrupt flag and get INT_STATUS byte mpuInterrupt = false; mpuIntStatus = mpu.getIntStatus(); // get current FIFO count fifoCount = mpu.getFIFOCount(); // check for overflow (this should never happen unless our code is too inefficient) if ((mpuIntStatus & 0x10) || fifoCount == 1024) { // reset so we can continue cleanly mpu.resetFIFO(); Serial.println(F("FIFO overflow!")); // otherwise, check for DMP data ready interrupt (this should happen frequently) } else if (mpuIntStatus & 0x02) { // wait for correct available data length, should be a VERY short wait while (fifoCount < packetSize) fifoCount = mpu.getFIFOCount(); // read a packet from FIFO mpu.getFIFOBytes(fifoBuffer, packetSize); // track FIFO count here in case there is > 1 packet available // (this lets us immediately read more without waiting for an interrupt) fifoCount -= packetSize; mpu.dmpGetQuaternion(&q, fifoBuffer); mpu.dmpGetGravity(&gravity, &q); mpu.dmpGetYawPitchRoll(ypr, &q, &gravity); Input = ypr[2] * 180 / M_PI; PID1.Compute(); //Output to motor shield control_motor(Output); //Display Euler angles in degrees Serial.print("ypro\t"); Serial.print(ypr[0] * 180 / M_PI); Serial.print("\t"); Serial.print(ypr[1] * 180 / M_PI); Serial.print("\t"); Serial.print(ypr[2] * 180 / M_PI); Serial.print("\t"); Serial.println(Output); } } void control_motor(double pwm_value) { int pwm = round(pwm_value); if (pwm < -255) pwm = -255; if (pwm > 255) pwm = 255; if (pwm > 0) { //Set the motor direction CW digitalWrite(4, LOW); digitalWrite(5, HIGH); analogWrite(9, pwm); //Set the motor speed } else { //Set the motor direction CCW digitalWrite(4, HIGH); digitalWrite(5, LOW); analogWrite(9, pwm); } } But once I connect my arduino uno board and launch the program I get this error message: Arduino: 1.8.13 (Windows 7), Board:"Arduino Uno" V2:1:10: fatal error: I2Cdev.h: No such file or directory #include "I2Cdev.h" ^~~~~~~~~~ compilation terminated. exit status 1 I2Cdev.h: No such file or directory ZIP file does not contain a map or valid library What do I need to do? Thanks for any help. Very welcome when you don't have any arduino experiences !!! Kind regards,